Hard problems,
made to work.
Daisuke Kuriyama — software and robotics engineer. Multi-agent path finding (MAPF), web performance engineering, and developer profiling & verification tools. Benchmarks and design notes are published here.
- ISUCON13 TVer Award
- League of Robot Runners 2026 — Combined Track Top 10 Award (6th Place)
- Ghostty / Rust / Material UI / Zig contributor
- Founder of BreakAI
Engineering focus
Software & Performance Engineering
Bottleneck analysis and tuning for high-throughput web systems, CLI & profiler tooling, and upstream patches to Ghostty, Rust, Zig, and Material UI.
Robotics & Path Planning
Multi-agent path finding (MAPF) and collision/deadlock avoidance for warehouse AGV/AMR fleets, plus VDA 5050 protocol verification.
Explore multi-robot coordination at RovnouInstrumentation & Profiling
Building single-binary profilers (isutools) unifying SQL, HTTP, nginx, and pprof traces, along with behavioral event tracking and A/B test pipelines.
Selected works
Public software, competition results, and engineering write-ups with reproducible benchmarks.
ROBOTICS / MAPF
League of Robot Runners 2026
6th Place (Top 10 Award) in the 1,000-robot Combined Track of the Amazon Robotics-sponsored competition as solo team Rovnou.
SOFTWARE / OSS
isutools
Single-binary profiler for Go web services (OSS / MIT). Collects and diffs SQL, HTTP, nginx, and pprof metrics with a one-line import.

PERFORMANCE
ISUCON14: 2,175 → 567,694 pts
Step-by-step tuning log of the ISUCON14 benchmark (ISURIDE), resolving 10 bottlenecks from 2,175 to 567,694 points.
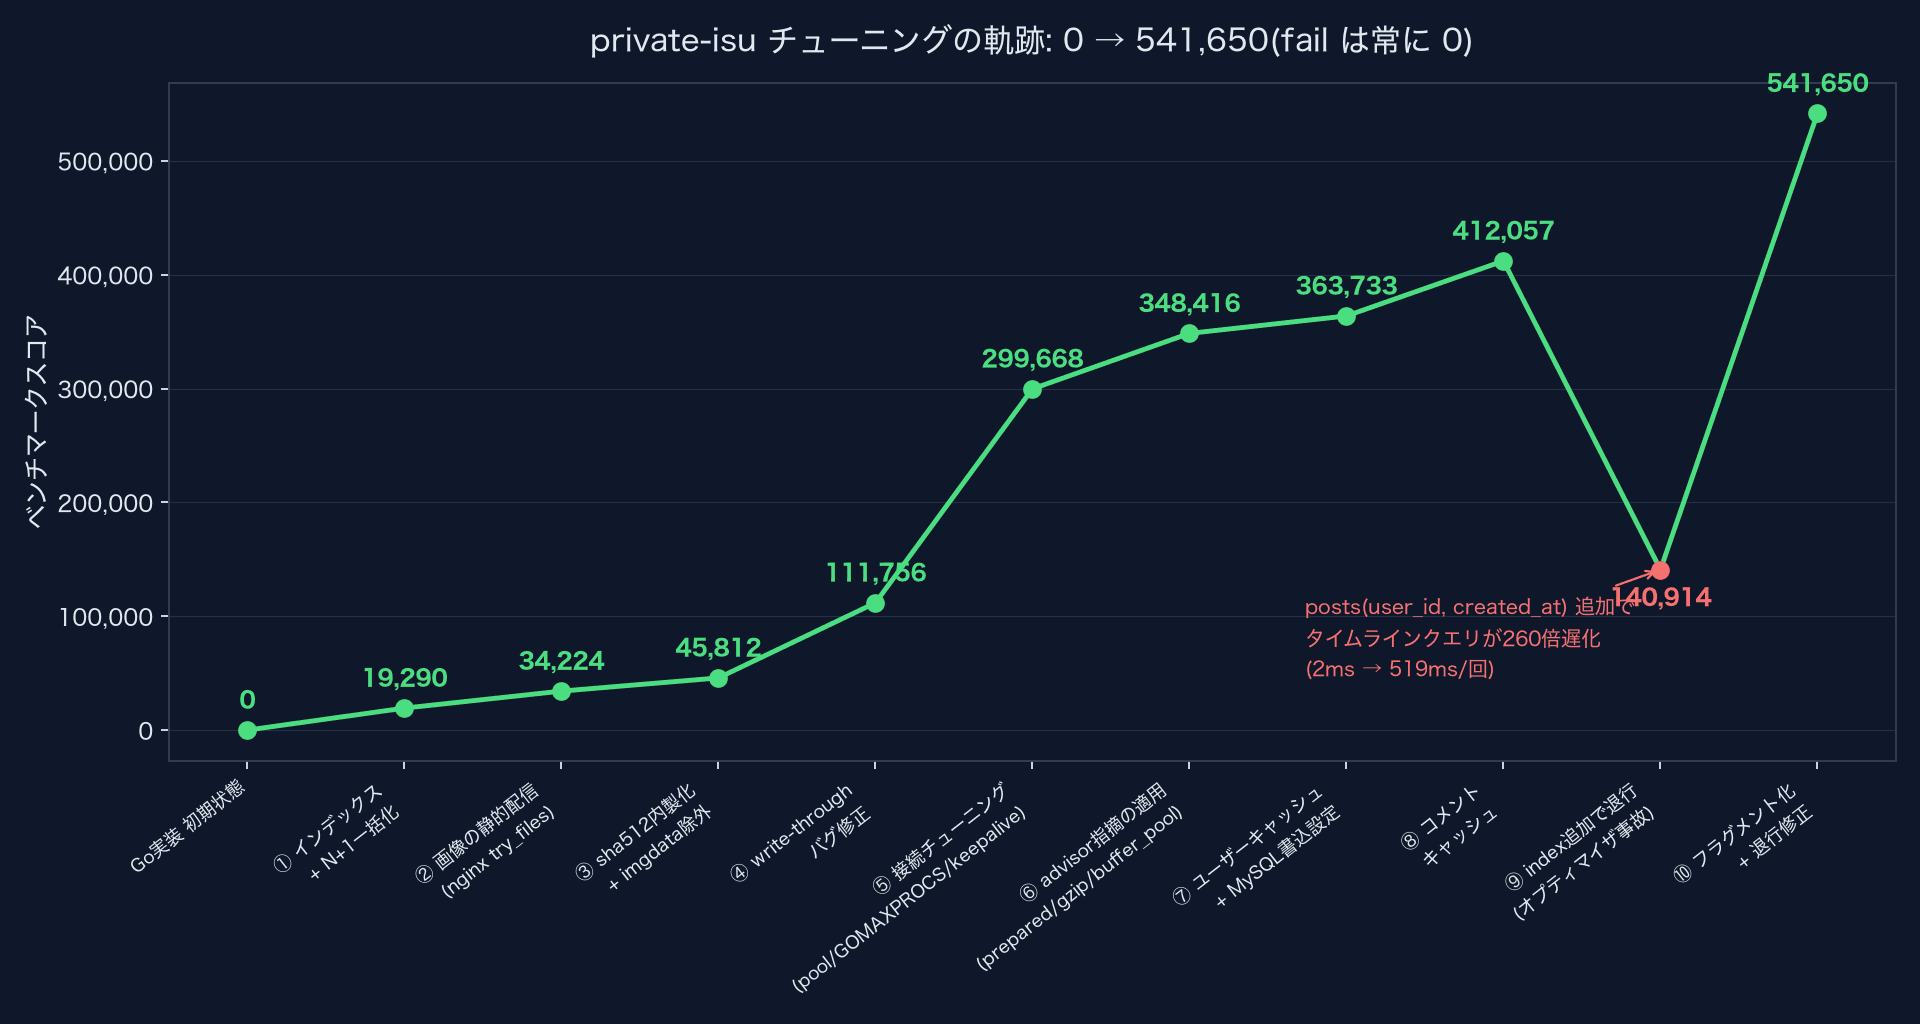
PERFORMANCE
private-isu: 541,650 points
Measurement-driven tuning log taking a web application from 0 to 541,650 in one day, with before/after numbers for all 10 commits.
ROBOTICS / OSS
vda5050-lab
Rust CLI and web viewer for validating VDA 5050 multi-vendor AGV/AMR MQTT traces and diagnosing fleet deadlocks (OSS / MIT).
PRODUCT
LLMonster
Mobile AI agent triggered directly from the iOS/Android system share sheet.
SECURITY
Gogyo Security
Self-assessment web tool for METI's Supply Chain Security (SCS) evaluation framework — no registration required.
OSS
Ghostty / Rust / Material UI / Zig
Upstream patches to Ghostty (tmux control-mode screen & parser state restoration), the Rust compiler (rustc), Material UI, and Zig.
MEASUREMENT
Behavioral Measurement & Conversion Design
Event schema design, A/B testing, and funnel reporting pipelines for landing pages.
Latest articles
Architecture trade-offs, failed attempts, and benchmark numbers from actual projects.
How Team “なんかいい感じではやいやつ” (ekusiadadus) Lost ISUCON 2026 (ISUREAL), and the Rematch to 544,004 Points
A retrospective by ekusiadadus of team “なんかいい感じではやいやつ” at ISUCON 2026 (ISUREAL). On contest day our in-memory rewrite failed the reboot consistency check and we lost. In a rematch on November 3 we rebuilt it as a fully in-memory design where a sequencer on asia2 gives every write a global order, and reached a self-best of 544,004 points on the portal. Past 500k, the limit was the benchmarker, not our servers.
Reading Existing Ghostty Tabs from TTYbird
Implementing a UUID-directed Ghostty output snapshot in TTYbird, alongside macOS Accessibility (AX) findings and clipboard restoration design.
Why the Latest Codex ISUCON14 Run Trailed the Historical Claude Record
The score gap is real, but hardware, durability, missing optimized application source, and different optimization paths prevent a fair model ranking.
Astra Solo vs. Astra + GPT-5.6 Sol: Two Three-Hour ISUCON11 Studies
A controlled Codex SDK rerun narrowed the post-reboot gap to 2.3%, while Astra solo still recorded the higher peak with fewer tokens.
Media coverage
This site was featured in Levtech Freelance's roundup of engineering blogs. The article is in Japanese.
最新技術から開発の舞台裏まで!エンジニアの学びを支えるブログ(external site)Work together
Available for technical consulting, joint R&D, and engineering engagements in multi-robot path planning (MAPF), web performance tuning, and profiling/measurement infrastructure.
Email meRobotics & MAPF / Performance Engineering / AI Agents / Instrumentation